 2d3 Ltd has won a contract from the Netherlands MOD yesterday to upgrade the ScanEagle UAS motion imagery exploitation capability.
Category Archives: Electronic Sub-Systems
PrecisionHawk’s Low Altitude Tracking and Avoidance System
 PrecisionHawk Inc., Unmanned Aerial Vehicle (UAV) manufacturer and Aerial Data Processing and Analysis Company, has announced a solution, known as LATAS (Low Altitude Tracking and Avoidance System,) for the safe integration of drones into the National Airspace.
Smaller Lidars Allow UAVs to Conduct Underwater Scans
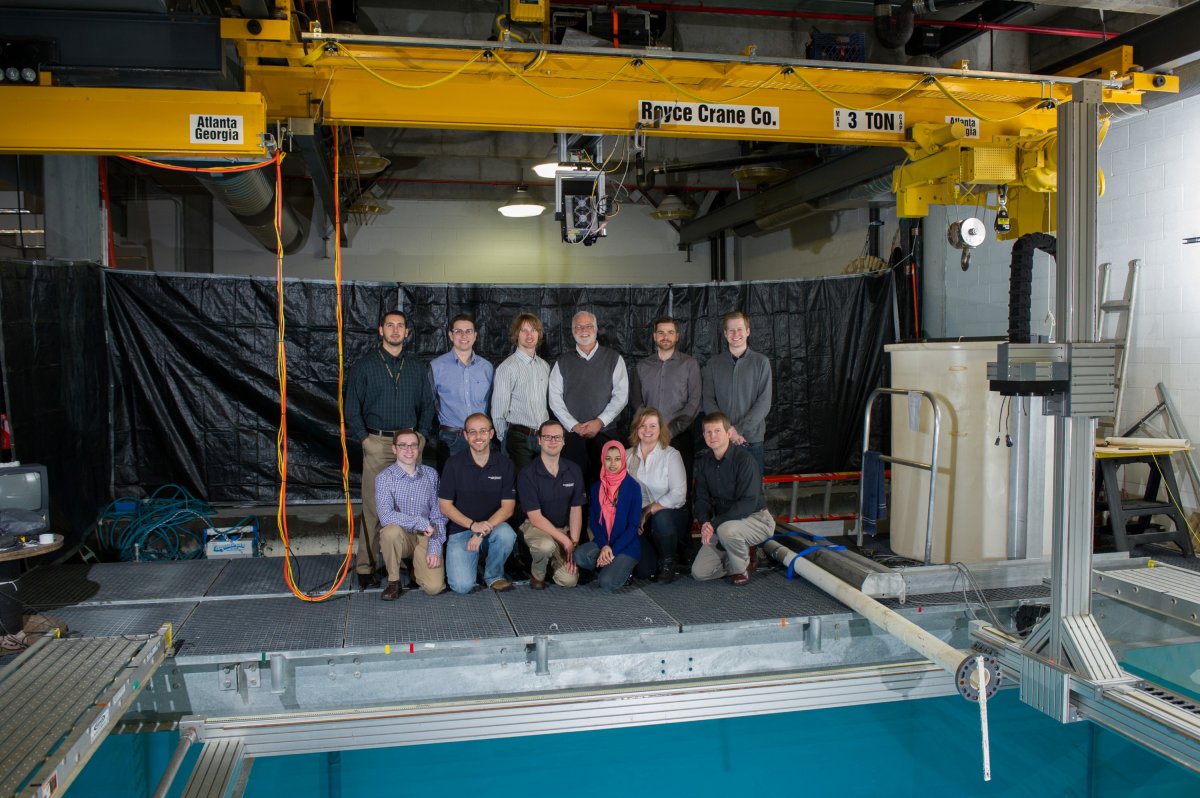 A team at the Georgia Tech Research Institute (GTRI) has designed a new approach that could lead to bathymetric lidars that are much smaller and more efficient than the current full-size systems. The new technology, developed under the Active Electro-Optical Intelligence, Surveillance and Reconnaissance (AEO-ISR) project, would let modest-sized unmanned aerial vehicles (UAVs) carry bathymetric lidars, lowering costs substantially.
QinetiQ Launches New Airborne Surveillance System
 QinetiQ has launched a new range of airborne communications surveillance systems at Farnborough Airshow. The ASX system is modular with a range of configurations allowing it be used on large, medium and small manned or unmanned aircraft.
MicroPilot Celebrates 20th Birthday
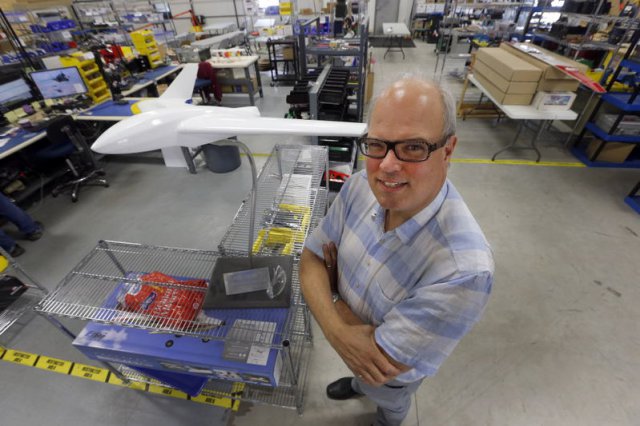 Stony Mountain company, MicroPilot, is celebrated its 20th anniversary last weekend and Howard Loewen hopes someday — maybe within the next five years — his company might become an overnight success. MicroPilot makes autopilot technology — autonomous flight operating systems — for unmanned aerial vehicles.
Northrop to Upgrade Kearfott Navigation Systems in MQ-8B/C Fire Scout
 U.S. Navy unmanned aircraft system (UAS) experts plan to upgrade navigation systems in the Northrop Grumman MQ-8B/C Fire Scout shipboard unmanned helicopters to improve the UAS precision and reliability.
GE Aviation Fields New ‘Turnkey’ UAS Computers

GE Aviation has unveiled a new family of computing platforms designed to provide a common software environment to host a variety of unmanned and manned aircraft mission computing applications. The goal of the new platform is to reduce the cost of developing software for new aircraft programs. GE claims its new computing platform can host a range of different applications, including vehicle management, mission payload, aerial refueling, navigation and communication management. Continue reading
Flying-Cam Adopts QNX Operating System
 QNX Software Systems Limited, a provider of software platforms for connected embedded systems, and Flying-Cam, a designer and manufacturer of unmanned aircraft systems, have announced that the QNX Neutrino operating system is powering the Flying-Cam 3.0 SARAH unmanned aircraft system, which has won a Scientific and Technical Award from the Academy of Motion Picture Arts and Sciences. Continue reading